MISE benchmark
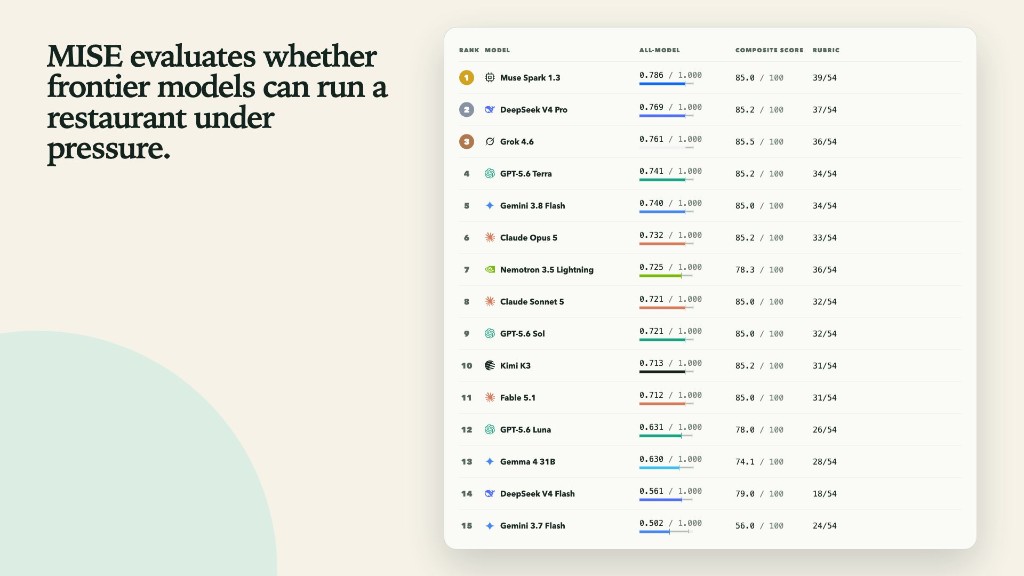
I made 19 frontier models run a restaurant, built a playable version to collect human traces for post-training, live-demoed it at True Ventures' Scrappy Sessions, and separately presented it to Mercor's Code Data team at Mercor HQ.
I made 19 frontier models run a restaurant, built a playable version to collect human traces for post-training, live-demoed it at True Ventures' Scrappy Sessions, and separately presented it to Mercor's Code Data team at Mercor HQ.
1st Overall @ DiamondHacks 2026
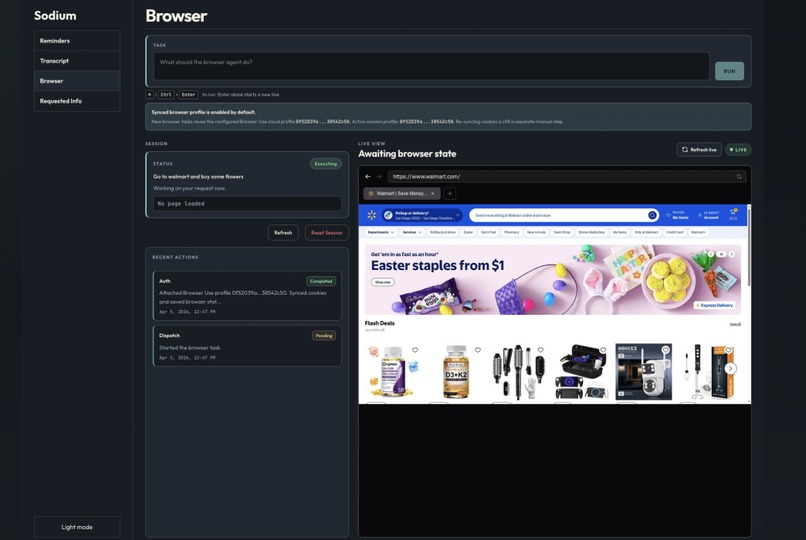
Voice-first AI companion for senior care: an autonomous robot with natural speech interaction, wake-word detection, medication reminders, crisis detection, and a caregiver monitoring dashboard. Frontend built with Svelte 5 and Bun runtime for a lightweight, responsive experience.
1st Overall @ OpenClaw Hackathon Eragon x Nozomio x AgentMail
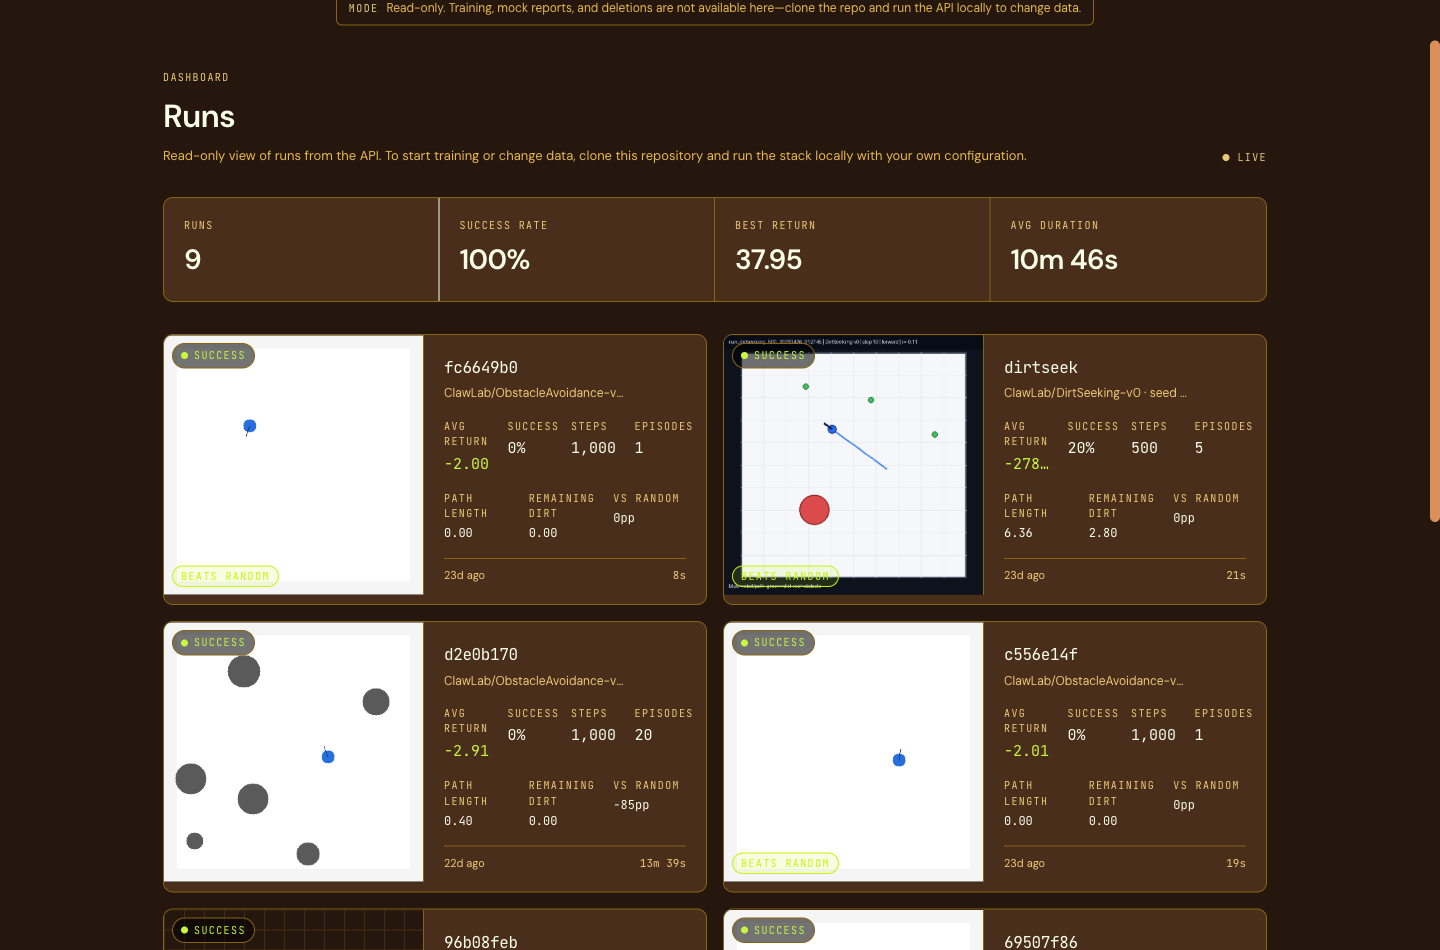
RL training orchestrator for a 2D Roomba cleaning sim that automates the full workflow: FastAPI trains PPO agents, evaluates them, generates GIFs, and delivers results through email (AgentMail), memory (Nia), and MCP tools for autonomous agent-driven optimization.
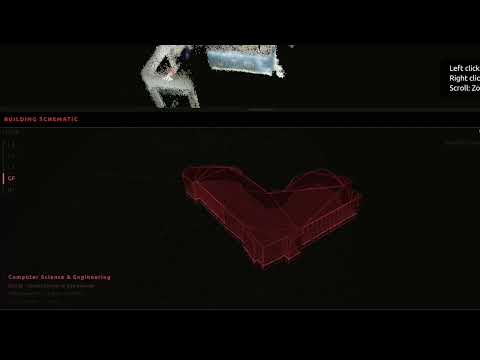
1st Overall @ transpose/compiled-5 UCSD Hackathon
Navigation, Incident Guidance, and Emergency Localization & Control — a mission-control interface for the Future Interfaces hackathon. Think air traffic control for firefighters: helmet VSLAM point clouds, multi-unit video feeds, radio transcripts, and tactical mapping in one dispatcher dashboard.
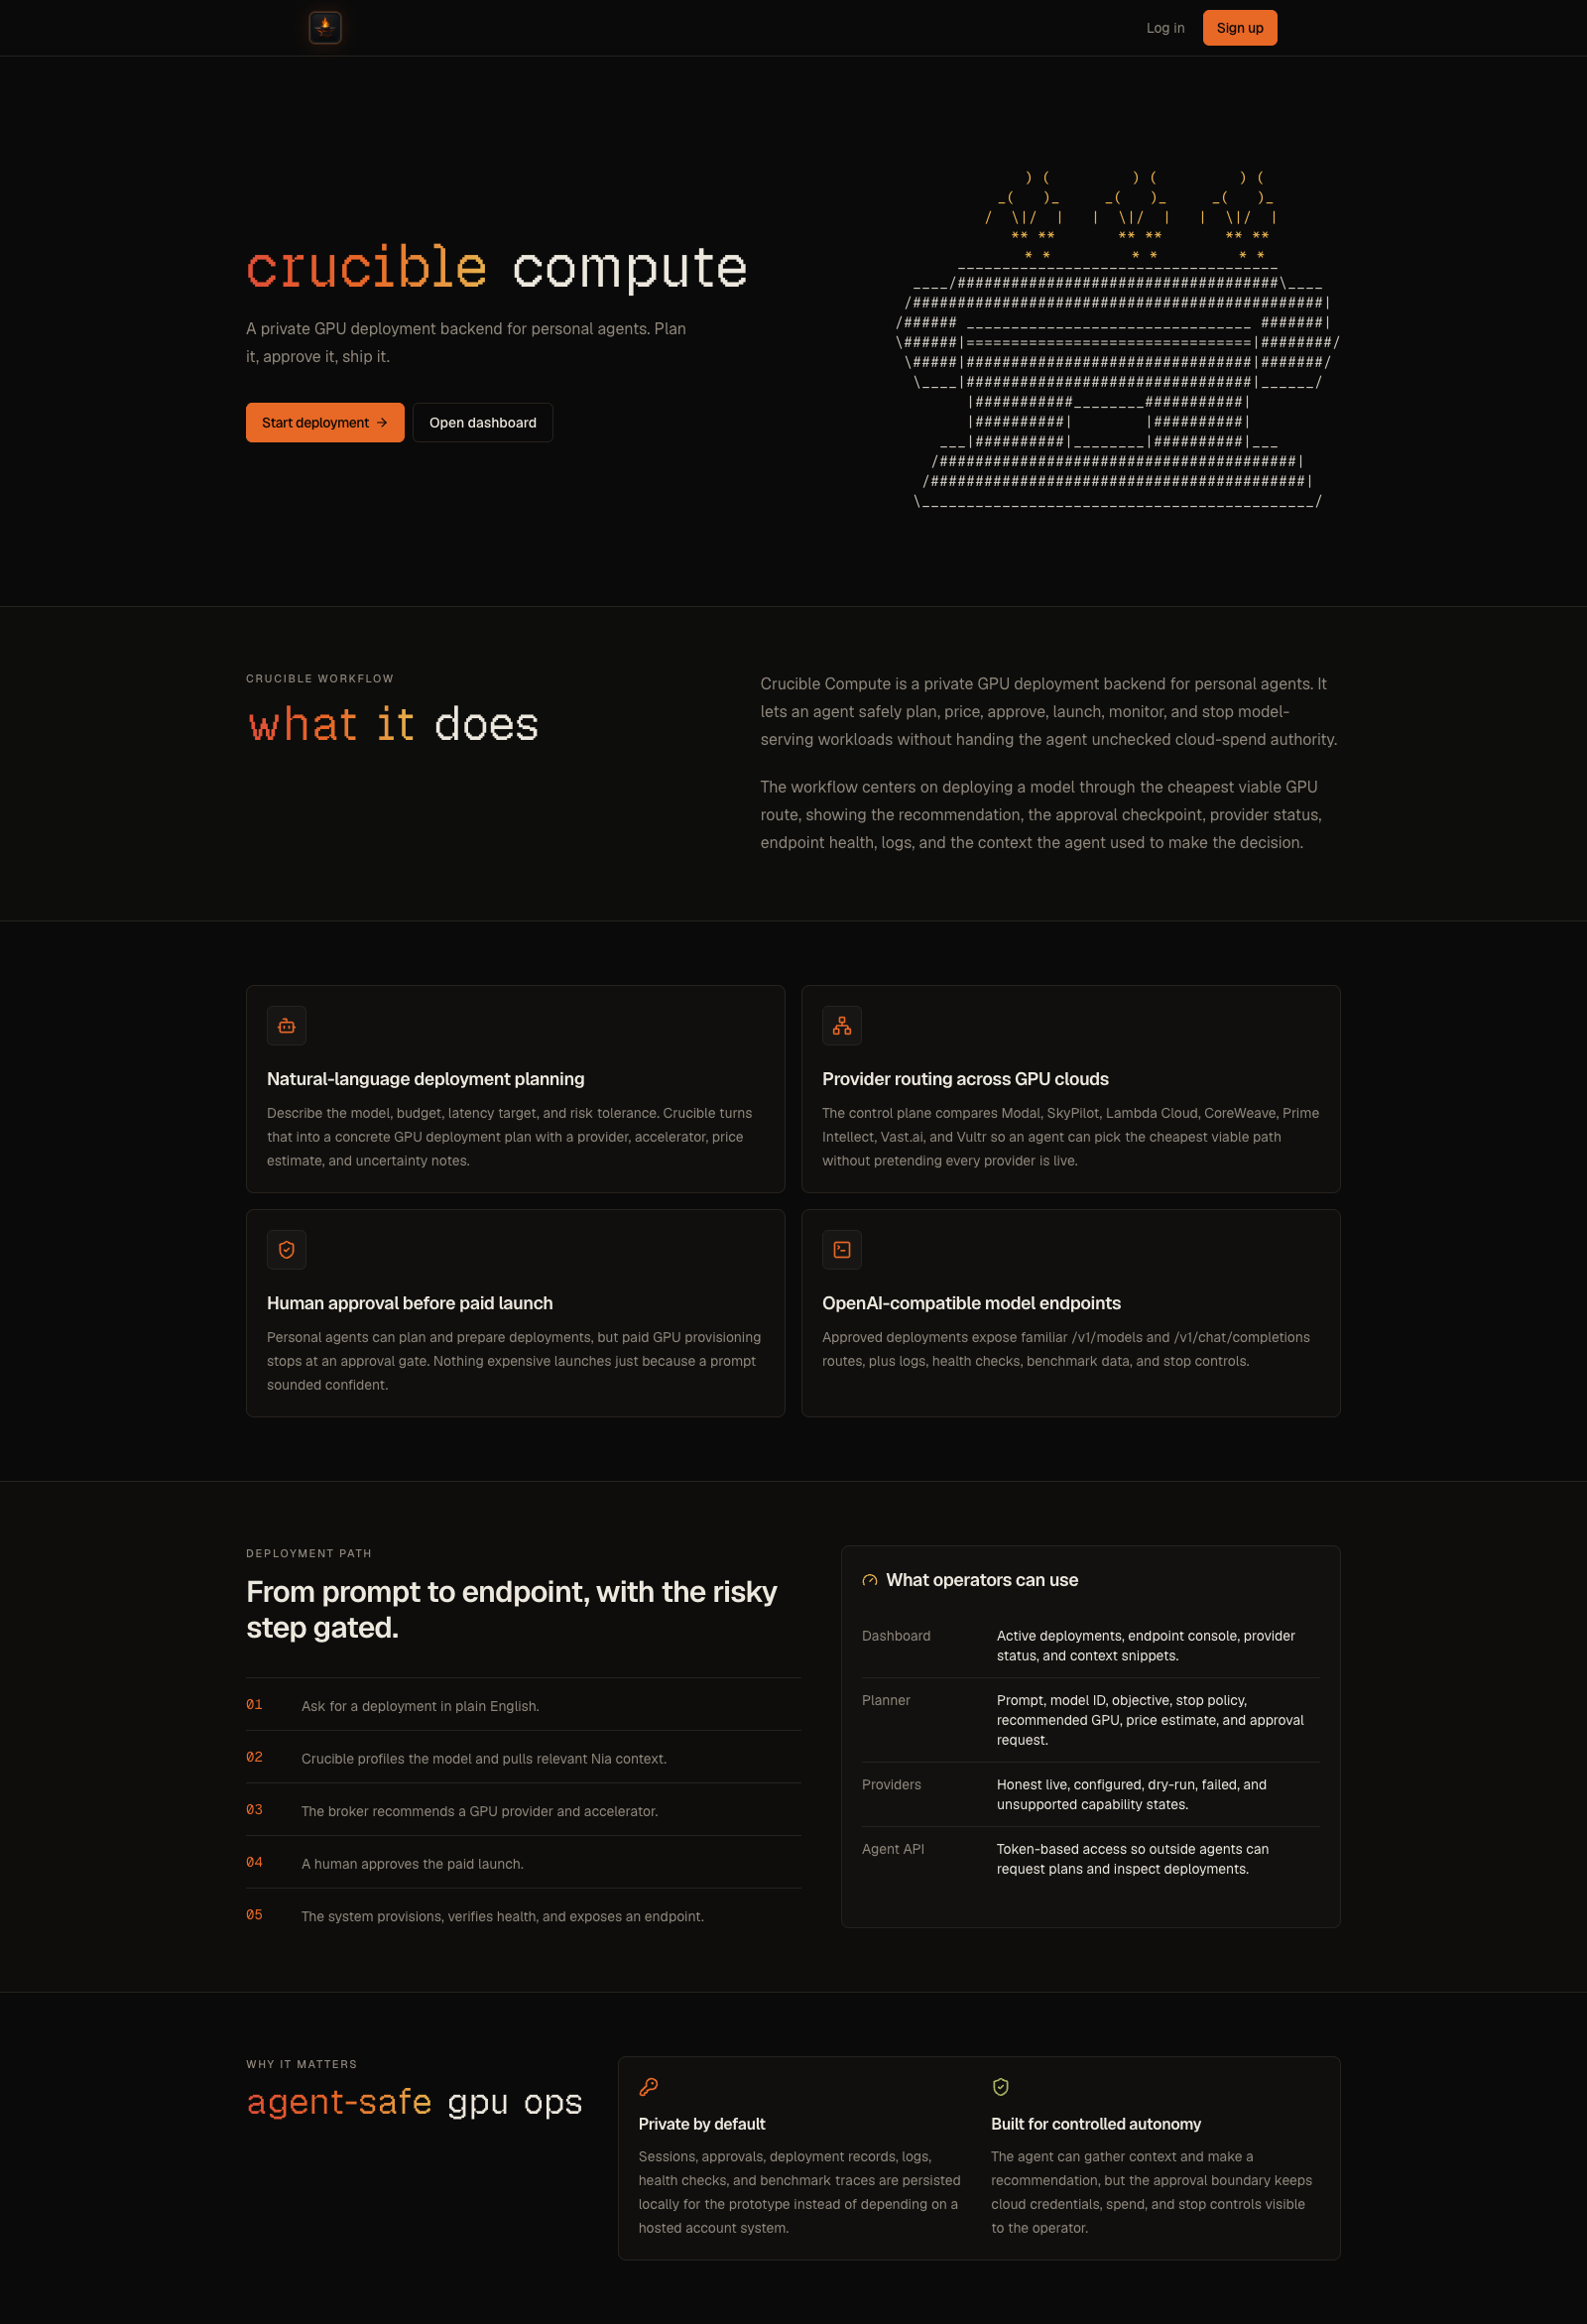
5th Place @ Nozomio Hackathon
Deploy GPUs with natural language and find cost arbitrage across cloud providers. A control plane that routes inference workloads across local Docker, Kubernetes, Vultr, Vast, and llama.cpp while automatically finding the cheapest, fastest hardware matches for your models.
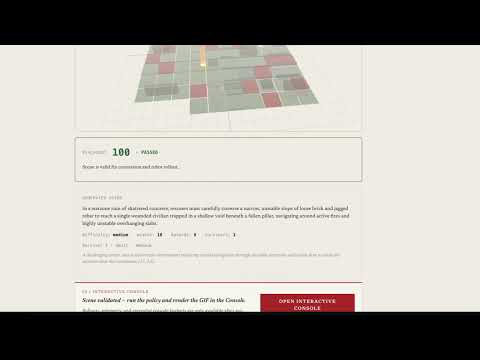
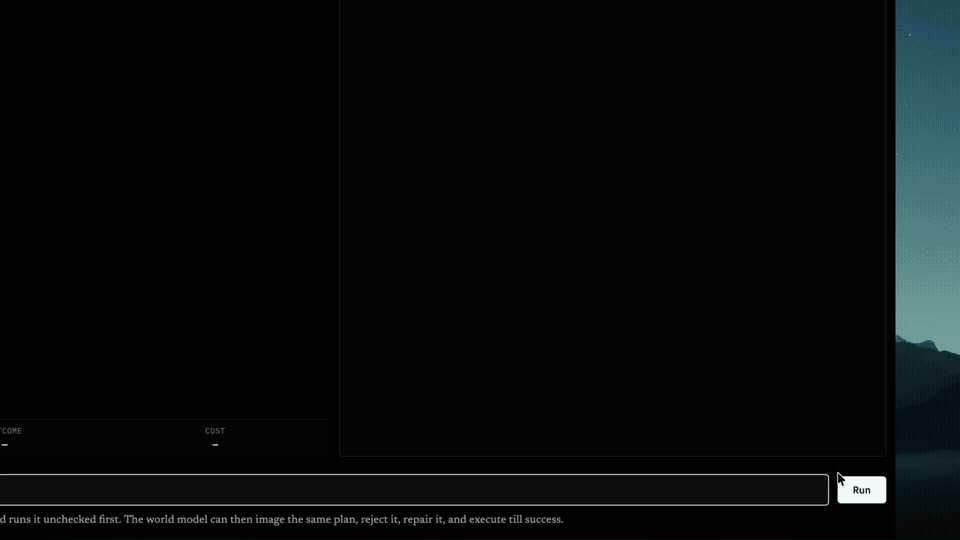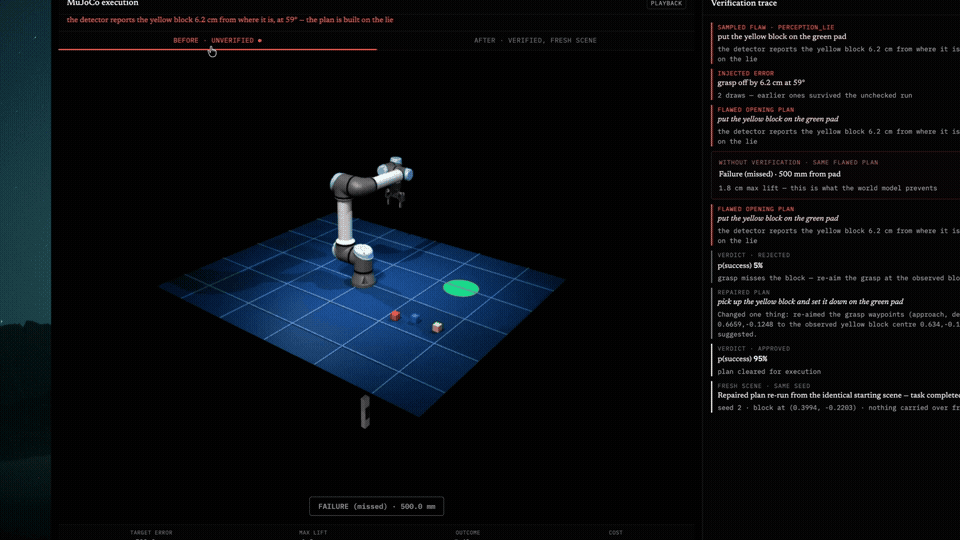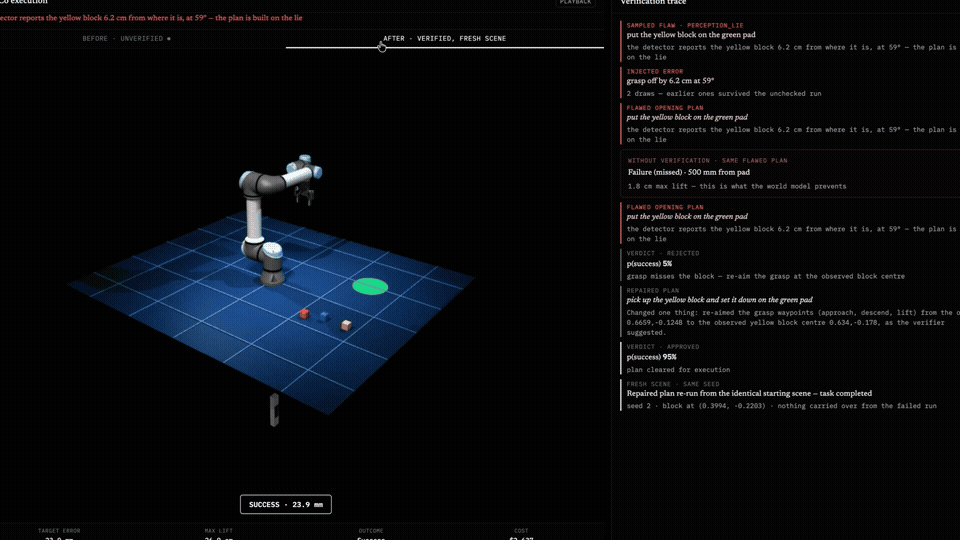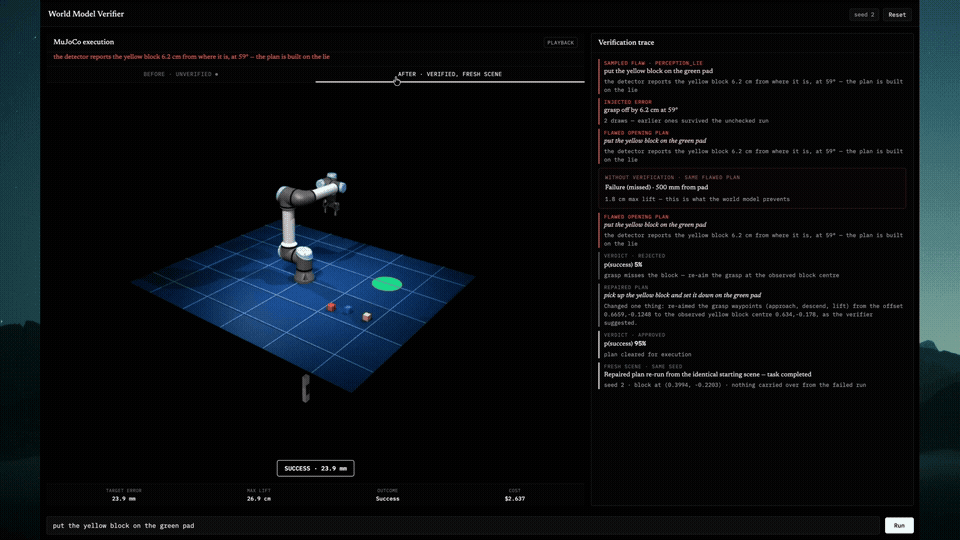
Rescue mission control for simulated disaster response. PPO training on eight MuJoCo simulation environments, Gemini environment generation, and a language-driven console with live rollouts and GIF replay.